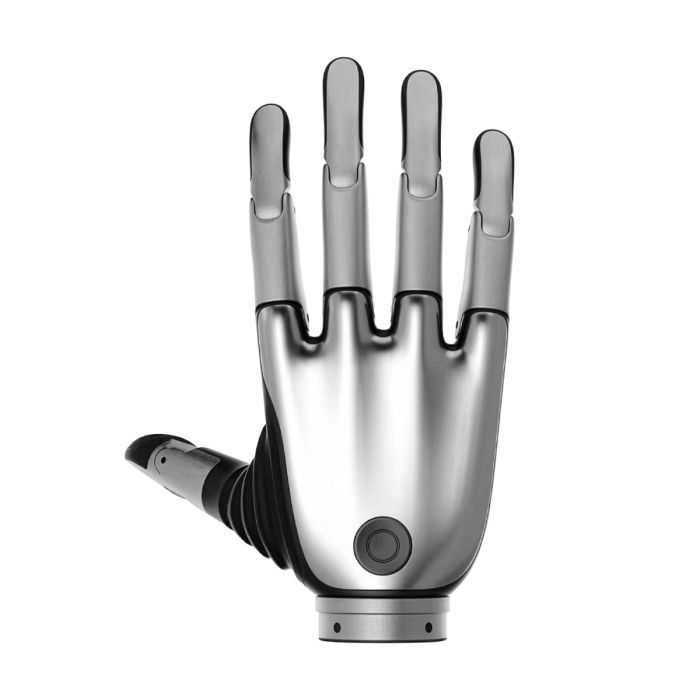
BrainCo Revo 2 Pro Dexterous Right Hand (XER)
In stock
- BRAND:
- BRAINCO
- MODEL:
- REVO 2 PRO
- PART #:
- XER
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-2-Pro
BrainCo Revo 2 Pro Dexterous Right Hand (XER)
Count the joints that move under power and the joints that merely follow, and the design of a hand becomes clear. The BrainCo Revo 2 Pro Dexterous Right Hand (XER) offers 6 active joints that together give 11 degrees of freedom. A small number of actuators therefore shapes a rich range of finger motion, and that is the central idea behind this bionic hand for robot integration and research.
This product is available through this page, by quotation.
Background
BrainCo and the Revo 2 family
BrainCo is the manufacturer of the Revo line of bionic dexterous hands. The second generation, Revo 2, is offered in three versions, each in a left-hand and a right-hand configuration: Basic (XRL/XRR), Pro (XEL/XER) and Touch (XTL/XTR). The XER described here is the right-hand model of the Pro version. Its left-hand counterpart is the BrainCo Revo 2 Pro Dexterous Left Hand (XEL).
Readers who wish to see the whole family side by side may visit the BrainCo Revo 2 category, or the wider Hands category for other end-effectors. Pairing a left and a right hand of the same version is a natural choice for a bimanual platform, because both hands then share one control approach and one software environment.
Positioning and key technology
The Revo 2 is a bionic dexterous hand for robot integration and research. That purpose places it firmly in the laboratory and the integration bench rather than in the showroom. The hand is driven by closed-loop servo control, which means that finger motion is regulated against feedback and not merely commanded open-loop. Custom gesture definitions allow a team to store its own hand poses and call them up as needed.
The hand also carries protections for current, stall, high temperature and collision conditions. In practical terms, these protections matter most during development, when a new grasping routine meets an object for the first time and something may go wrong. Software support covers Linux, Windows and ROS workflows, so the hand can be brought into the toolchain that a robotics team already uses.
The Pro version is distinguished by its communication options. It supports three interfaces, namely 485, CAN FD and EtherCAT, and these are located below the wrist. A team can therefore select the bus that suits its robot instead of redesigning the controller around the hand.
Technical Specifications
| Specification | Value |
|---|---|
| Product type | Bionic dexterous hand for robot integration and research |
| Version and code | Pro, right hand (XER); the left hand is XEL |
| Active joints | 6 |
| Degrees of freedom | 11 |
| Thumb | Two active degrees of freedom for abduction and adduction; one passive degree of freedom for flexion and extension |
| Index, middle, ring and little fingers | Each has one active and one passive degree of freedom for flexion and extension |
| Communication interfaces | 485, CAN FD, EtherCAT (interface located below the wrist) |
| SDK support | Linux, Windows and ROS workflows |
| Control | Closed-loop servo control; custom gesture definitions |
| Protections | Current, stall, high temperature and collision |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, the wrist mounting dimensions, the material, the IP rating or the service life; they are confirmed at quotation.
How do 6 active joints produce 11 degrees of freedom?
The answer lies in the split between active and passive motion. The thumb has two active degrees of freedom, for abduction and adduction, and one passive degree of freedom for flexion and extension. Each of the other four fingers has one active and one passive degree of freedom for flexion and extension. Adding these together gives six active joints and eleven degrees of freedom in total.
For an integrator, this has a direct consequence. Only six joints need to be commanded, so the control problem remains manageable, while the hand still presents a finger arrangement that resembles a human one. A research group studying grasp strategies can concentrate on a small set of controlled variables without giving up the thumb movement that makes opposition possible.
What does the Pro version add to the Revo 2 family?
The clearest difference documented for the Pro is its communication choice. It supports 485, CAN FD and EtherCAT, with the interface located below the wrist. A robot that already uses EtherCAT for its joints can treat the hand as one more device on the same network. A simpler bench set-up can use 485 or CAN FD instead.
The Basic version is available as the BrainCo Revo 2 Basic Right Dexterous Bionic Hand (XRR). The Touch version is available as the Brainco Revo 2 Touch Biomimetic Dexterous Right Hand (XTR). The advanced and tactile versions are also documented with the three interfaces, so the interface choice should be compared with the version page of any alternative before an order is placed. Every figure on this page belongs to the Pro version and should not be read across to a sibling.
Who is the BrainCo Revo 2 Pro Dexterous Right Hand (XER) for?
The first segment is the university or institute laboratory that studies manipulation. These teams value a hand with documented joint structure, SDK support for Linux, Windows and ROS, and protections that tolerate experimental error. The second segment is the humanoid and mobile-manipulation developer, who needs a right-hand end-effector that connects to an existing controller over a recognised industrial or embedded bus.
The third segment is the systems integrator preparing a demonstration or a pilot cell, where the hand must be wired, configured and put through repeated routines. For buyers who need a matching left hand, the XEL listed above is the natural companion. Those whose project does not require the three-interface choice may wish to examine the Basic version instead, while those interested in the tactile version may review the Touch page.
What is the BrainCo Revo 2 Pro Dexterous Right Hand (XER) used for?
- Robot integration: mounting the hand as the right end-effector of a humanoid or manipulator platform.
- Manipulation research: testing grasp strategies and finger coordination with a defined set of six active joints.
- Control development: tuning closed-loop servo behaviour over 485, CAN FD or EtherCAT.
- Gesture programming: defining custom gestures and calling them from software.
- Software prototyping: building applications with the SDK on Linux, Windows or within ROS workflows.
- Protected trials: running new routines with current, stall, high-temperature and collision protections in place.
Pricing and Availability
Pricing for the BrainCo Revo 2 Pro Dexterous Right Hand (XER) is provided by quotation, and no figure is shown on this page. Delivery, customs and support are arranged together with the quotation, so that the full scope is clear before an order is confirmed. Please send your enquiry with the robot platform and the intended communication interface, and the quotation can be prepared accordingly. The product is available on this page.
Frequently Asked Questions
Is the XER a right-hand or a left-hand model?
The XER is the right-hand model of the Pro version. The left-hand model of the same version is the XEL.
Which communication interfaces does it support?
It supports 485, CAN FD and EtherCAT. The interface is located below the wrist.
How many joints and degrees of freedom does it have?
It has 6 active joints and 11 degrees of freedom. The thumb has two active and one passive degree of freedom, and each of the other four fingers has one active and one passive degree of freedom.
Which software environments are supported?
The SDK supports Linux, Windows and ROS workflows. Closed-loop servo control and custom gesture definitions are included.
What protections does the hand include?
It includes protections for current, stall, high temperature and collision conditions.
Are the dimensions, IP rating and service life available?
These details are settled at quotation, together with the wrist mounting dimensions and the material. Please state them in your enquiry if they decide your integration.
Where can I buy the BrainCo Revo 2 Pro Dexterous Right Hand (XER) and what does it cost?
It is available through this page, by quotation. The cost is given in the quotation and not shown here, so please send an enquiry to receive it.
Summary
The interest of this hand lies in its economy: six active joints giving eleven degrees of freedom, a choice of 485, CAN FD and EtherCAT below the wrist, and protections that suit development work. It is aimed at teams that integrate and research rather than merely display. The Pro version adds communication flexibility within a family that also includes Basic and Touch versions. For a quotation on the XER, this page is the starting point.
Specifications
General
Physical
Mobility
Performance
Connectivity
Software
Hand
Feature
1. High quality and stability – five years of product iteration and professional production lines.
2. Lightweight (383 grams), with 5 kg active grip force, 20 kg single-hand load capacity, and a grip-to-weight ratio of 53.
3. Ergonomic Bionic Design – supports curved surface grasping with anti- collision finger design.
4. Multi-dimensional tactile perception – pressure, friction, direction, proximity, and surface texture.
5. High Sensitivity Tactile Perception – max resolution of 0.01N.
6. Wide voltage support – 64V.
7. Universal Interfaces – RS485 & CAN-FD, and EtherCAT.
8. Standard Protocols and SDKs – Modbus & Protobuf protocols, SDKs for Python / C / ROS.