RoboParty RP Hand
In stock
- BRAND:
- RoboParty
- MODEL:
- RP Hand
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- RoboParty-RP-Hand
RoboParty RP Hand
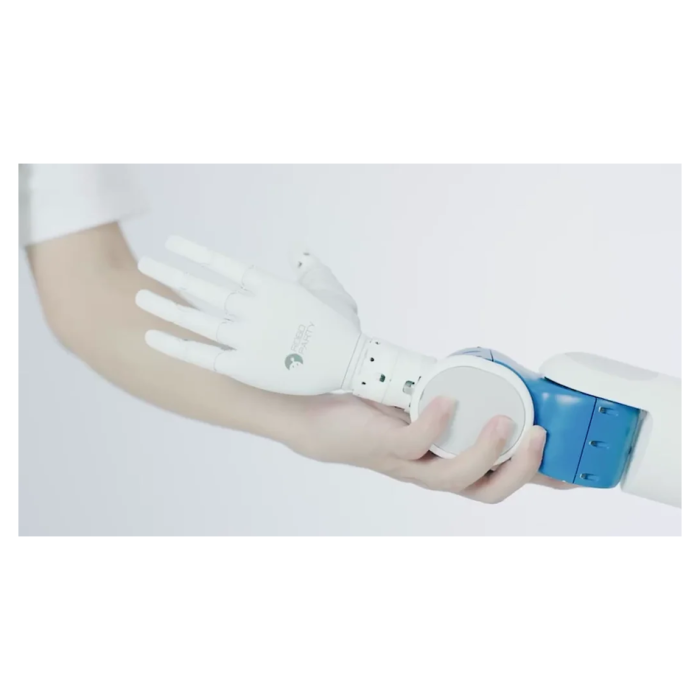
RoboParty RP Hand is a slim dexterous robotic hand intended for humanoid robot integration. Its published design combines 11 total degrees of freedom with six active degrees of freedom in a 379 g assembly, subject to a ±10 g mass tolerance. It is an end-effector product rather than a complete robot, and its integration requirements should be evaluated separately from the specifications of a host humanoid.
Dimensions and Articulation
The manufacturer lists a length of 147.54 mm, width of 73.53 mm and thickness of 26.35 mm. These are product dimensions rather than shipping dimensions. The compact thickness and stated mass provide useful starting points when assessing wrist packaging and distal mass, although the host robot’s mechanical interface still needs to be checked against the manufacturer’s dimension drawing.
Motion is transmitted through a worm-gear mechanism. Published thumb lateral movement is 0°–87.5°, thumb flexion and extension is 0°–65°, and bending of the four fingers is 0°–72°. Directional resolution is listed as 1°, and the minimum opening-and-closing time is ≤0.7 seconds. Total and active degrees of freedom describe different aspects of the mechanism and should not be collapsed into an unsupported claim of 11 independent actuators.
Power and Drive Electronics
RP Hand accepts an input-voltage range described as 12 V (-10%) to 48 V (+10%). Static current is listed as ≤0.1 A and maximum current as ≤2.5 A. The motor description specifies brushless coreless motor modules, paired with an integrated multi-in-one driver and miniature encoders. These figures are component specifications, not a complete host-system power budget.
An integration review should confirm the selected supply, connectors, wiring and operating configuration against the relevant documentation. The source does not provide a universal mounting adapter or state compatibility with every humanoid wrist. It also does not publish a rated grip force or payload for the hand in this product-page specification, so those values should not be inferred from its motors, current or optional sensors.
Optional Tactile Sensing
Palm and five-finger tactile sensors are configurable options. For the optional palm sensor, the manufacturer lists normal-force measurement with 0.1 N resolution and a 0–25 N measurement range. For the optional finger sensors, tangential and normal force are identified, with 0.01 N resolution and a normal-force measurement range of 0–20 N. Tangential direction spans 0°–360°, with 1° directional resolution.
These values apply only to the relevant tactile-sensor configuration. They describe sensing range and resolution, not the force the hand is guaranteed to exert on an object. A system intended for contact-feedback experiments should therefore specify which sensor package is included and verify access to the corresponding data. A hand without that option must not be described as providing the same tactile measurements.
Communications and Software Integration
The communication list includes EtherCAT, CAN FD and RS485, with an important qualification: CAN FD and RS485 are alternative configurations. The page should not be read as guaranteeing all listed buses in the same delivered configuration. Protocol choice belongs in the quotation and integration requirements, alongside the host controller and cabling plan.
Supported development platforms are Windows, Linux and ROS 2, with x86 and ARM architectures. C++ and Python are listed as development languages. Available tools include a visual host application, an open SDK and example programmes. Model files are offered in URDF, MJCF and STEP formats, covering robot-description, simulation and mechanical-design workflows. Teams should still verify the current package versions and their applicability to the hardware ordered.
Service-Life and Environmental Figures
The source lists 250,000 unloaded opening-and-closing cycles and 250,000 loaded cycles. The loaded figure is tied to a full-load side-grip condition; one cycle means one opening and one closing. A three-year design service life is also listed. These statements should be kept with their stated context and should not be rewritten as a warranty, a guaranteed lifetime in every task or a measured life under unspecified loads.
Operating temperature is -10 to 45 °C, operating humidity is 10%–90% RH and storage temperature is -10 to 70 °C. The manufacturer gives an IP30 protection rating. This is a published product rating rather than evidence of independently verified certification, and it should not be expanded into a claim of weatherproof or washdown-ready operation.
Applications and Procurement
RP Hand is relevant to humanoid manipulation research, hand-motion integration and, with optional sensors, contact-feedback experiments. Successful use depends on the host robot’s wrist interface, control system and power arrangement. The available software and model files support development, but they do not establish that a particular grasping policy or complete autonomous manipulation application is supplied.
A quotation should identify the hand configuration, communication option, tactile package and required development files. Confirm the actual mounting arrangement and supplied accessories before ordering. No source selling price, shipping mass, lead time or commercial warranty is asserted in this draft.
Frequently Asked Questions
What is RoboParty RP Hand?
It is a dexterous humanoid-robot end effector with 11 total degrees of freedom, six active degrees of freedom and a stated mass of 379 g ±10 g.
How does RP Hand move?
Brushless coreless motor modules drive a worm-gear mechanism. The manufacturer publishes separate thumb and finger motion ranges and a minimum opening-and-closing time of ≤0.7 seconds.
Does RP Hand include tactile sensors?
Palm and five-finger tactile sensing is optional. The published tactile measurement ranges and resolutions apply only when the corresponding sensor configuration is selected.
What are its development benefits?
The listed SDK, examples and URDF, MJCF and STEP files support software, simulation and mechanical integration across the stated platforms and architectures.
Where can I buy RP Hand?
Use RoboParty’s official RP Hand page to request the required configuration. Confirm communication selection, optional sensing, mechanical compatibility and commercial terms before ordering.
Summary
RP Hand combines a slim mechanical layout with documented motion, electrical and development interfaces. The key purchasing distinctions are its total versus active degrees of freedom, the selected communication configuration and whether optional tactile sensors are supplied.